
The company’s presentation, themed "From Touch to Intelligence," centers on a three-layer architecture that integrates perception, data acquisition, and world modeling. The foundation rests on the DM-Tac series, vision-based sensors boasting over 110,000 sensing units capable of capturing high-frequency data across twelve tactile modalities. These sensors are supported by the Data-Nexus system, which streamlines the pipeline for generating interaction data, and the Daimon-TWM world model, which grounds robotic decision-making in physical feedback.
In section Releases
Daimon Robotics Debuts Tactile Infrastructure for Physical AI at IROS
At the IROS 2026 conference in Pittsburgh, Daimon Robotics is moving beyond visual perception to address the physical limitations of modern automation. The company unveiled a full-stack tactile intelligence infrastructure designed to provide robots with the capacity to feel force, slip, and material response, enabling more dexterous real-world manipulation.
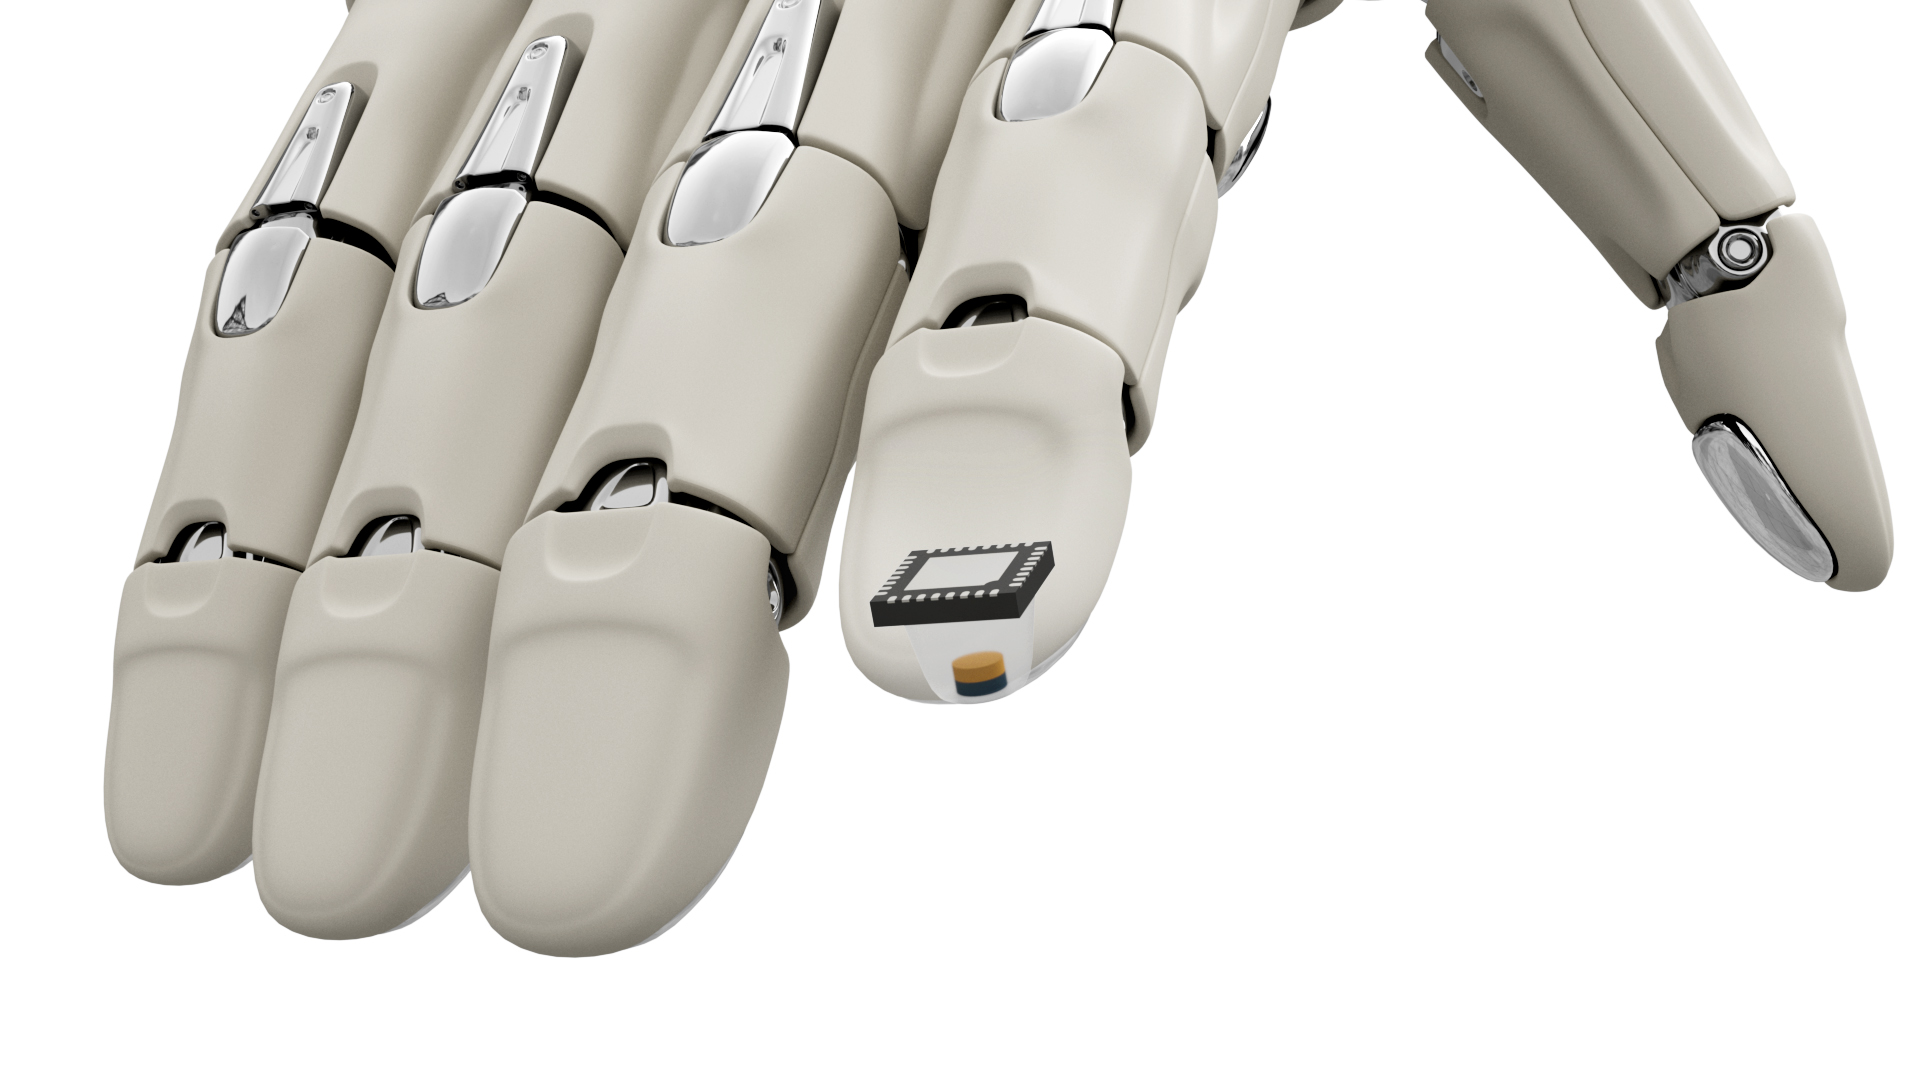
Demonstrating these capabilities publicly for the first time since its August launch, the Daimon-TWM model powered two autonomous tasks at the booth. In a bead-stringing demonstration, the system navigated small-scale precision and deformable materials without relying on pre-programmed motion sequences. A second task involved heat-transfer printing on canvas totes, requiring the robot to manage multi-step, long-horizon operations—such as film removal and hot stamping—by continuously adjusting its movements based on real-time tactile input. Founded in 2023 by researchers from The Hong Kong University of Science and Technology, the Shenzhen-based firm aims to shift robotics from simple observation to nuanced physical interaction.
Comments (0)
No comments yet. Be the first!